Long-horizon autonomy
RSI systems and context management support agentic, long-horizon autonomous research.
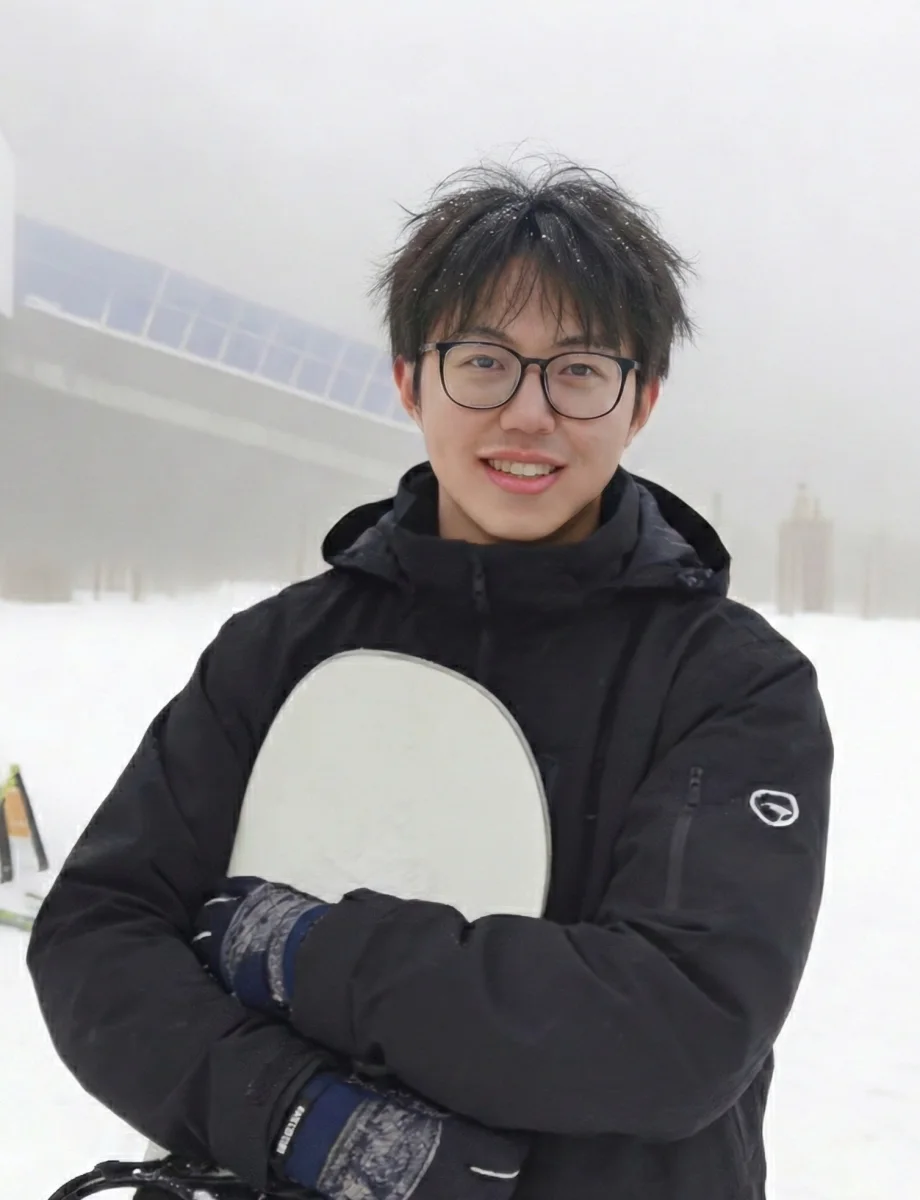
Zixing “Elwood” Lei · PhD Student, Shanghai Jiao Tong University · Google Scholar ↗
Supervised by Prof. Siheng Chen, I focus on Recursive Self-Improvement, Reinforcement Learning, and Embodied AI. I believe that using powerful agents to reshape today’s scientific and engineering R&D pipelines is a critical path toward a superintelligent future.
RSI systems and context management support agentic, long-horizon autonomous research.
RL environments and algorithms let agents explore autonomously and acquire efficient, learnable signals.
Embodied AI grounds agents in the physical world, where intelligence can be tested and verified.
No papers in this research direction.
A hierarchical navigation runtime connects language-model reasoning with a low-latency action policy. Separate reasoning, acting, and monitoring threads manage context and control, enabling interruption handling and human-level success on RxR-CE.
Read paper ↗An information-constrained video-action framework uses a dynamics-aware bottleneck to suppress irrelevant visual detail while retaining action-relevant cues, improving manipulation performance and robustness under out-of-distribution shifts.
Read paper ↗ Project page ↗An Experiment OS regularizes experimental actions and preserves traceable records, while reviewer-guided orchestration explores a growing research graph. Together they reduce hacking and strategy lock-in during autonomous model improvement.
Read paper ↗NavMCP scaffolds a VLM reasoning agent with a navigation foundation model through intent, observation, and memory, enabling persistent long-horizon embodied exploration without retraining and achieving state-of-the-art EQA and strong real-robot results.
Read paper ↗ Project page ↗A scalable pipeline that turns egocentric human manipulation videos into 18,561 hours of robot training data across 15 morphologies, improving out-of-distribution generalization for vision-language-action models.
Read paper ↗ Watch video ↗VLAs-as-Tools separates temporal reasoning from local physical execution, enabling high-level agents to plan, select specialized VLA tools, monitor progress, and recover over long horizons.
Read paper ↗An autonomous data-engineering agent that searches, constructs, evaluates, and remembers data interventions to improve a fixed learning algorithm through downstream feedback.
Read paper ↗A benchmark that reconstructs end-to-end physics research workflows to evaluate long-horizon reasoning, autonomous exploration, and objectively verifiable scientific outcomes.
Read paper ↗EmboCoach-Bench evaluates agents that iteratively design, debug, and optimize embodied policies through environment feedback, spanning reward design and policy architecture.
Read paper ↗A scalable training ground combining large-scale task generation, distributed simulation, and multi-level rewards so language models can acquire decision-making skills through embodied interaction.
Read paper ↗A whole-body control training platform that jointly trains policies across heterogeneous simulators, reducing simulator bias and enabling zero-shot deployment on a real humanoid robot.
Read paper ↗A communication-adaptive spatiotemporal recovery framework that uses historical information, knowledge distillation, and curriculum learning to restore cooperative perception under V2X interruptions.
Read paper ↗FreeAlign estimates relative pose and timing from shared object geometry, enabling robust collaborative perception without relying on external localization or clock signals.
Read paper ↗CoBEVGlue matches co-visible objects to recover relative poses, making collaborative perception robust to localization noise and adversarial pose errors.
Read paper ↗An interactive sketch question-answering task and multi-round emergent communication system balancing answer accuracy, drawing complexity, and human interpretability.
Read paper ↗Spatial confidence maps identify perceptually critical regions to share, preserving multi-agent perception performance while dramatically reducing communication.
Read paper ↗SyncNet compensates asynchronous features through attention-based estimation and time modulation, improving collaborative perception under communication latency.
Read paper ↗A study of communication disruptions in collaborative perception that recovers missing information from historical observations to maintain robust detection performance.
Read paper ↗No technical reports in this research direction.
A scalable navigation model with a reconfigurable observation strategy, allowing a high-level planner to switch task modes and context strategies during long-horizon execution.
Read paper ↗A generalizable vision-language-action foundation model that aligns heterogeneous manipulation data across representation, motion, and behavior to enable large-scale training and cross-embodiment transfer.
Read paper ↗A language-conditioned video world model that predicts physically grounded futures across manipulation, autonomous driving, navigation, and human-to-robot transfer.
Read paper ↗A unified embodied foundation model for manipulation, navigation, and trajectory prediction, extending vision-language reasoning into continuous action generation across robot embodiments.
Read paper ↗An infrastructure-and-orchestration stack for traceable, reproducible long-horizon scientific workflows, turning diverse scientific assets into reusable agent-ready capabilities.
Read paper ↗Education and industry.
 Shanghai Jiao Tong University
Ph.D., School of Artificial Intelligence
2024 – 2027expected
Shanghai Jiao Tong University
M.Eng., Cooperative Medianet Innovation Center
2021 – 2024
Shanghai Jiao Tong University
B.Eng., Electronic Engineering · Outstanding Engineers Class
2017 – 2021
 Tongyi Qwen
Core contributor of Qwen-Robot Suite (Manip and Nav)
2026 – Present
 ByteDance
Multimodal LLM Engineer, DATA
2024
 Intel
Graphics Software Engineering Intern, IAGS
2020 – 2021